Fixed-wing UAV
Autonomous fixed-wing UAV with computer vision
Autonomous flight and real-time computer vision for a fixed-wing UAV: OpenCV detects and classifies ground targets by colour and shape, and DroneKit flies the mission around what it sees.
My roleAutonomy and computer vision software
- colour & shape target detection
- OpenCV
- autonomous flight
- DroneKit
- decisions from visual data
- Real time
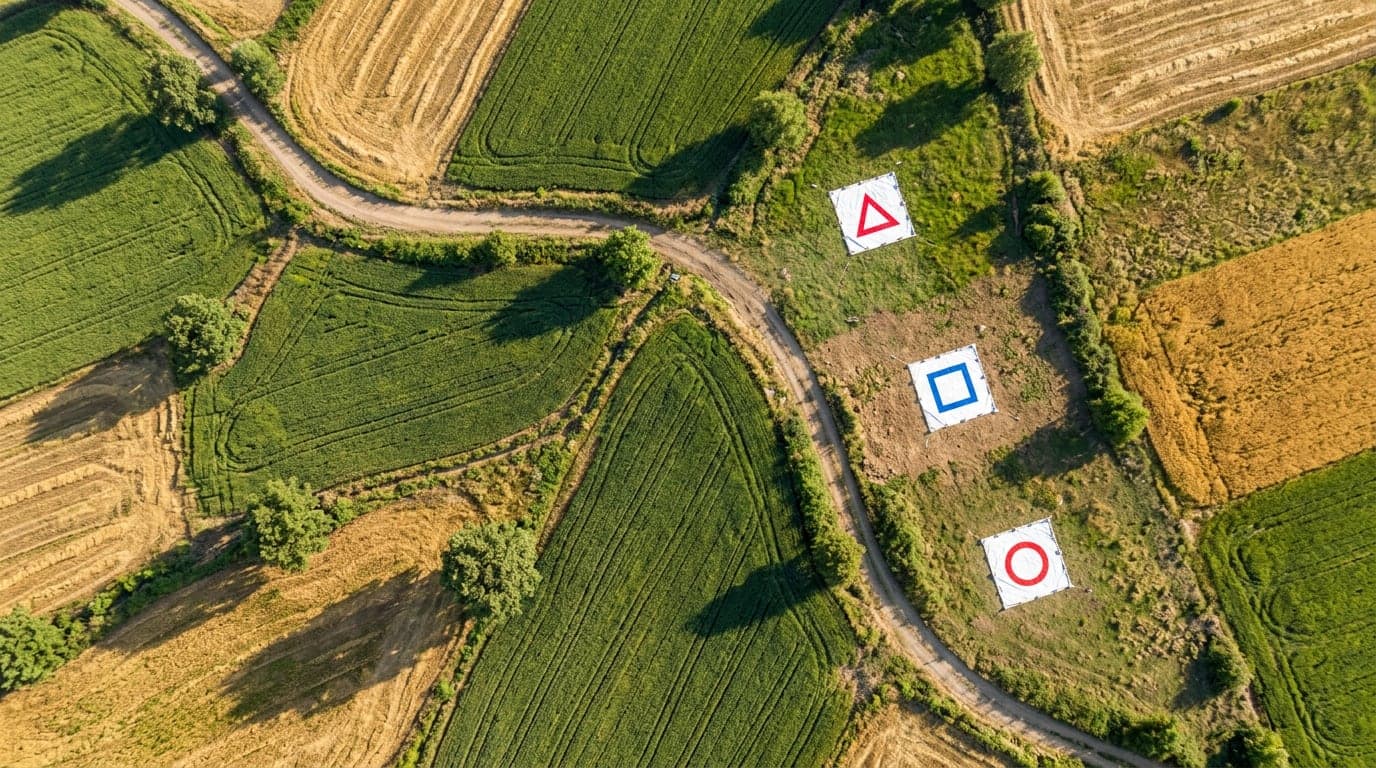
An autonomous flight and computer vision system for a fixed-wing UAV, combining real-time image processing with autonomous flight control.
OpenCV-based algorithms detect and classify targets from their colour and geometric characteristics. A DroneKit-based flight system controls the aircraft, processes flight data and runs predefined mission logic based on the detected targets, so decisions are made in real time from what the camera sees.
Built with
- Python
- OpenCV
- DroneKit
- Computer Vision
- Autonomous Flight
- UAV Systems
- Image Processing
- Embedded Systems
System architecture
How the system is put together
- VisionOpenCV pipeline detecting and classifying targets by colour and shape
- FlightDroneKit-based autonomous flight software
- MissionPredefined mission logic driven by detected targets
- DataCommunication between flight software and onboard sensors
- IntegrationVisual target information fed into the flight logic in real time